
Knot ($K: \mathbb S^1\rightarrow \mathbb R^3$ )
- 等价关系(isotopic, 同位, $K_1\cong_{isotopic} K_2$ ): 存在homeomorphism(同胚)映射 $f:\mathbb R^3\rightarrow \mathbb R^3$, 把$K_1$ 映到 $K_2$ .
- 全部knot都和$\mathbb S^1$ 是homeomorphism(同胚)
- Planar Diagram : knot在平面的投影, 记录方向和重叠部分的上下关系
- 同个knot的Planar Diagram可能有多种不同形式
判断两个knot等价(isotopic)
Reidemeister move (组合方法)
$K_1$ 的diagram由$K_2$ 的diagram经由四种基本移动变换得来 <-> $K_1\cong_{isotopic} K_2$
- 对Planar diagram的intersection做四种基本移动变换: (twist, untwist), (poke,unpoke), slide, straighten
- Np-hard 走的步数是节点数的指数倍?
Gordon-Luecke定理(几何方法)
$K_1$ 的补空间(3-manifold)和$K_2$ 的补空间同胚, 即 $(\mathbb R^3- K_1)\sim (\mathbb R^3-K_2)$ <-> $K_1\cong_{isotopic} K_2$
- 用Wirtinger表示 计算 $\pi_1(\mathbb R^3-K)$ ( 同胚<-> 基本群相同):
- 每个segment提供
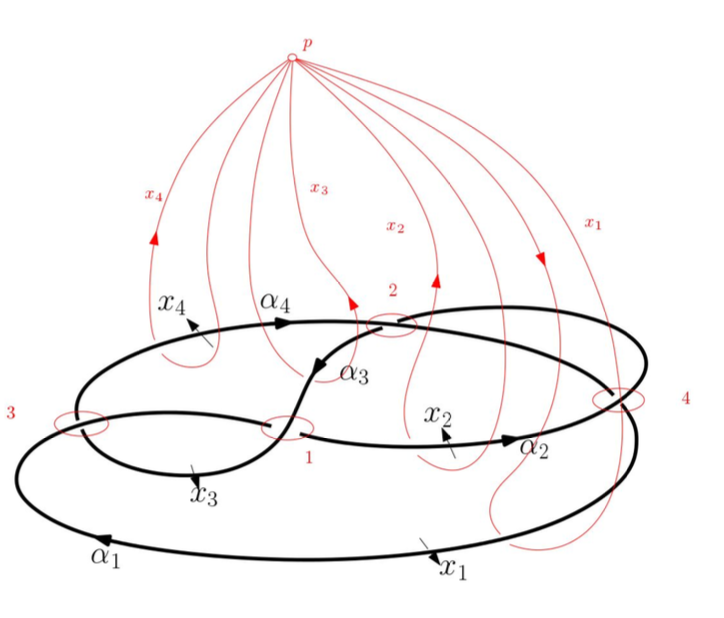 generators: $\lbrace x_1,x_2,\cdots,x_n\rbrace$
- 每个crossing提供
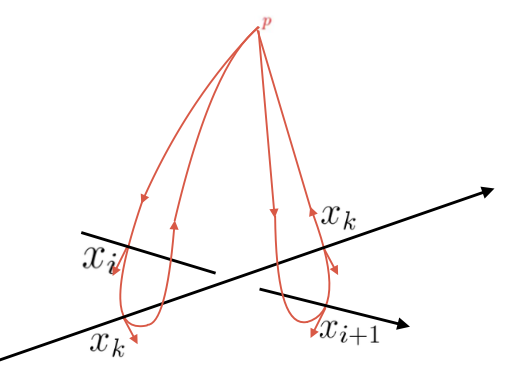 relation: $x_i\cdot x_k=x_k\cdot x_{i+1}$ (按照generator方向)
- relation会因为相互关联而化简
- 每个segment提供
knot genus
- knot genus 定义为Seifert surface中最小的genus: $g(K)=\min g(\Sigma)$
- 其中Seifert surface 是orientable曲面$\Sigma_K$ , 使knot $K$是曲面的边界: $\partial \Sigma=K$
- 因为diagram不同, 有多种不同的Seifert surface, 计算knot的genus是一个Np-hard问题
- 从diagram $D$ 构造Seifert surface $\Sigma_D$ :
- 方法: 给diagram一个orientation -> 沿crossing 分开成Seifert cycles -> 每个cycle填充disk -> 在crossing处加入twist
- Seifert Surface的genus $g(\Sigma_D)=\frac{1-s+n}{2}$
- $s$ 是Seifert cycles的个数, n 是crossing的个数
- connected sum $K_1 \texttt{#} K_2$
 把$K_1$, $K_2$ 沿某个点切开, 粘在一起
- connect sum的genus: $g(K_1 \texttt{#} K_2)=g(K_1)+g(K_2)$
knot分类(Trichotomy,三分法)
所有knot都属于torus knot, Satellite Knot, hyperbolic Knot三类
- torus knot: knot embed在torus的表面上
- (p, q)-torus knot: p是绕中间tunnel的圈数, q是绕handle的圈数(数crossing上下的规律)
- (3, 2)-knot(trefoil):
 (8,3)-knot:

- (3, 2)-knot(trefoil):
- (p, q)-torus knot: p是绕中间tunnel的圈数, q是绕handle的圈数(数crossing上下的规律)
- Satellite Knot: knot $K$ embed在一个torus knot $J$ 里面(大肠套小肠), 记作$Sat_J(K)$
- 分类:
- cable knot: 里面的knot $K$ 也是一个torus knot
- connected sum(composite knots): $K_1 \texttt{#} K_2$
- swallow-follow: $K_1$(Figure 8) 看起来像是被$K_2$ (trefoil) swallow
- swallow-follow: $K_1$(Figure 8) 看起来像是被$K_2$ (trefoil) swallow
- Whitehead doubles: 里面的knot $K$ 是 $S_1$ 经过一些twist首尾相连
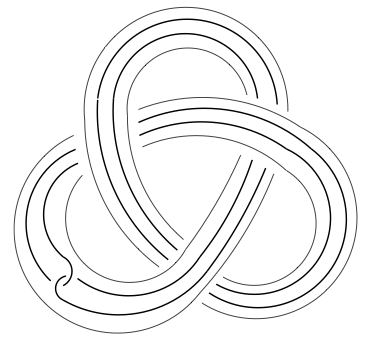 或,

- cable knot: 里面的knot $K$ 也是一个torus knot
- 分类:
- hyperbolic Knot: knot的补空间有一个complete, finite volume的双曲度量, 即补空间是hyperbolic 3-manifold(双曲三流型)
- 例如Figure 8 knot


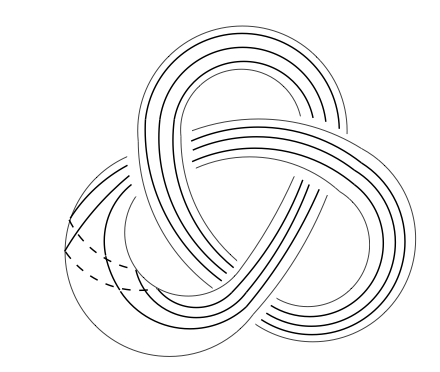
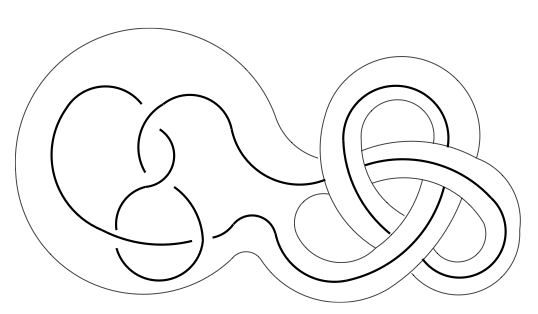
例子: Figure 8 Knot
Seifert surface和genus
Planar Diagram:  -> Orientation:
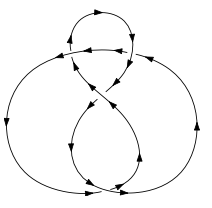 -> Seifert Cycles:
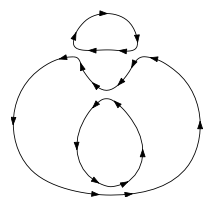 -> Fill Cycles:
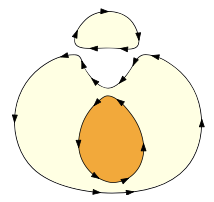 -> Add twists:
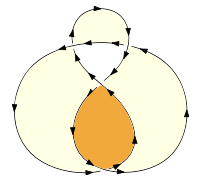 -> Seifert surface:

- 见图示, 有3个Seifert Cycles和4个crossing
- $g(\Sigma_D)=\frac{1-3+4}{2}=1$
Wirtinger表示
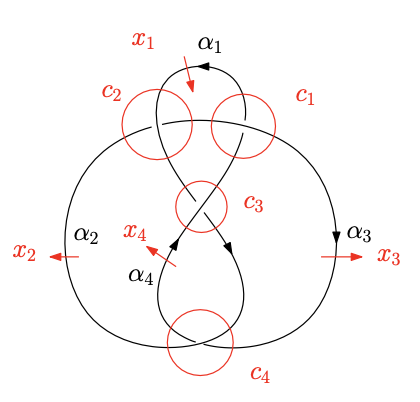
- 见图示, 4个segment对应生成元$x_1,x_2,x_3,x_4$ , 4个crossing对应relation $c_1: x_4x_3=x_3x_1$, $c_2:x_2x_1=x_1x_3$, $c_3:x_2x_4=x_4x_1$, $c_4: x_4x_2=x_2x_3$
- 化简得, 补空间的基本群 : $\pi_1(S^3-K)=<a,b\vert\ yay^{-1}=b>$
- 其中, $a=x_2, b=x_4$ , $y=[a^{-1},b]=a^{-1}bab^{-1}$
- 得到$\mathbb H^3$ 的tessellation: $a\mapsto A=\begin{bmatrix}1&-1\\ 0&1\end{bmatrix}$ , $b\mapsto B=\begin{bmatrix}1&0 \\ -\sigma & 1\end{bmatrix}$
- 其中, 根据relation解得, $\sigma=\frac{-1\pm i\sqrt{3}}{2}$
- 其映射: $\pi_1(S^3-K)\rightarrow Deck(\widetilde{S^3-K})\rightarrow \text{Isom}^{+}(\mathbb H^3)=PSL_2(\mathbb C)$
- $\widetilde{S^3-K}$ 是3-manifold $S^3-K$ 的universal covering space
- $\mathbb H^3$(Poincaré half-space) 是上半空间$\mathbb H^3=\lbrace(x,y,t)\vert\ t>0\rbrace$, 有双曲度量 $ds^2=\frac{dx^2+dy^2+dt^2}{t^2}$
- 是一个双曲三流型
- boundary $\partial \mathbb H^3=\mathbb C\cup\infty$ 又叫sphere at infinity
- $PSL_2(\mathbb C)$ 在$\mathbb C\cup \infty$ 上是Möbius transforms
reference
[1] https://www.math.ucdavis.edu/~jcs/pubs/satelliteknots.pdf satellite knot
[2] Coward, Alexander, and Marc Lackenby. “An Upper Bound on Reidemeister Moves.” American Journal of Mathematics 136, no. 4 (2014): 1023–66.
[3] “Tracefieldsknotes.Pdf.” Accessed July 20, 2024. https://julianlyczak.nl/seminar/knots2016-files/tracefieldsknotes.pdf. 双曲结构